← Back to Solutions

QDD Actuators for Exoskeletons

Backdrivable QDD actuator review for wearable and assistive robotics where low impedance, torque transparency, and compact packaging matter.

Target Buyer:Best for engineering teams evaluating QDD modules for wearable robot prototypes and controlled research platforms.
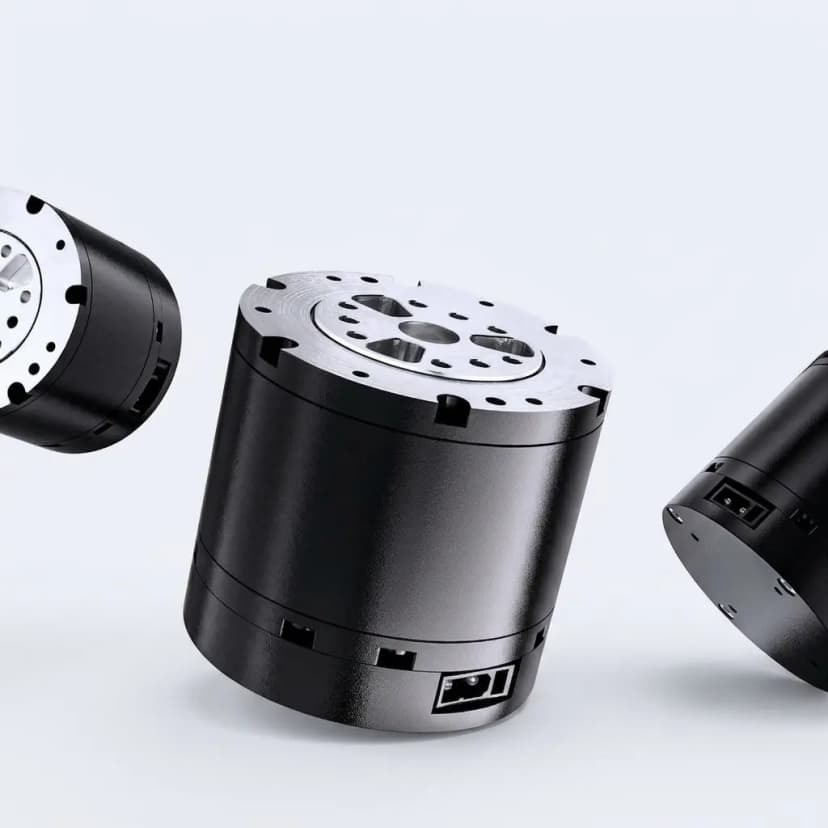
High-torque QDD actuator module for legged robot and exoskeleton joints

Solution Highlights

  • Low-impedance joint behavior for wearer interaction
  • Torque-control and encoder/interface review
  • Weight, noise, cable routing, and thermal comfort considerations

Common Use Cases

  • Lower-limb wearable robotics prototypes
  • Research exoskeleton joints
  • Assistive actuation platforms for lab validation

Implementation Focus

  • Backdrivability, torque transparency, and friction feel
  • Joint mass, package size, wearer-side heat, and noise
  • Encoder resolution, bus latency, current control, and safety architecture

Application Decision Summary

A buyer should use this page to decide which joint risks belong to actuator selection, which belong to system validation, and what sample evidence is needed before pilot purchase.

Best Evidence

Start with backdrive feel and connect it to the real robot duty cycle instead of reviewing catalog values alone.

Primary Risk

Wearer comfort is assumed from bench torque only

Next Buyer Action

Prepare joint location and wearable envelope plus validation targets before requesting samples or commercial terms.
Application Fit Method

Application pages should help a buyer decide whether the actuator direction fits the robot job before a commercial conversation starts.

Backdrive feel

<0.5 Nm backdrive for wearable comfort, <1.0 Nm acceptable for industrial

Wearable joints must not feel harsh or overly resistive when interacting with the user.

Mass and heat location

0.4–0.8 kg per joint, housing temp <50°C for skin-adjacent mounting

Weight and thermal comfort can dominate exoskeleton usability.

Control latency

<2 ms torque loop, <500 µs bus latency for natural motion feel

Low-latency torque response helps interaction and gait assistance research.

Robot-Level Validation Plan

The actuator should be checked against the robot motion cycle, not only against a bench specification.

Signal to CheckReview BasisEvidence to Ask For
Backdrive feel<0.5 Nm backdrive for wearable comfort, <1.0 Nm acceptable for industrialReview friction, mass, heat path, noise, and passive movement before selecting samples.
Mass and heat location0.4–0.8 kg per joint, housing temp <50°C for skin-adjacent mountingFrame actuator selection as engineering review and require the OEM to validate final system safety.
Control latency<2 ms torque loop, <500 µs bus latency for natural motion feelReview friction, mass, heat path, noise, and passive movement before selecting samples.

Acceptance Thresholds to Define

Define measurable pass/fail thresholds before the sample arrives. This prevents a subjective review where one team checks torque, another checks packaging, and nobody records whether the actuator can move toward pilot build.

  • Backdrive feel: Wearable joints must not feel harsh or overly resistive when interacting with the user.
  • Mass and heat location: Weight and thermal comfort can dominate exoskeleton usability.
  • Control latency: Low-latency torque response helps interaction and gait assistance research.

When This Application Needs Extra Review

Some application risks are system-level and cannot be solved by an actuator choice alone. Identify those risks before sample purchase.

  • Wearer comfort is assumed from bench torque only: Review friction, mass, heat path, noise, and passive movement before selecting samples.
  • Safety-critical claims are made before validation: Frame actuator selection as engineering review and require the OEM to validate final system safety.

Application Data to Send First

A useful application inquiry includes enough robot context for engineering to evaluate torque, packaging, control, and delivery risk together.

Fixed Constraints

  • Joint location and wearable envelope
  • Assist torque, speed, voltage, and duty-cycle target
  • Backdrivability and passive movement requirement

Review Targets

  • Encoder/interface preference and controller constraints
  • Prototype test environment and document needs

Application Evaluation Matrix

Evaluation MetricTypical RangeBuyer Relevance
Backdrive feel<0.5 Nm backdrive for wearable comfort, <1.0 Nm acceptable for industrialWearable joints must not feel harsh or overly resistive when interacting with the user.
Mass and heat location0.4–0.8 kg per joint, housing temp <50°C for skin-adjacent mountingWeight and thermal comfort can dominate exoskeleton usability.
Control latency<2 ms torque loop, <500 µs bus latency for natural motion feelLow-latency torque response helps interaction and gait assistance research.

RFQ Preparation Checklist

  1. Joint location and wearable envelope
  2. Assist torque, speed, voltage, and duty-cycle target
  3. Backdrivability and passive movement requirement
  4. Encoder/interface preference and controller constraints
  5. Prototype test environment and document needs

Risk and Mitigation

  • Wearer comfort is assumed from bench torque only: Review friction, mass, heat path, noise, and passive movement before selecting samples.
  • Safety-critical claims are made before validation: Frame actuator selection as engineering review and require the OEM to validate final system safety.

Recommended Products

QDD module for high-torque legged robot and wearable robotics applications
Quasi-direct-drive actuator module for dynamic legged robot validation
Integrated 14 Nm QDD actuator module for compact robot joints
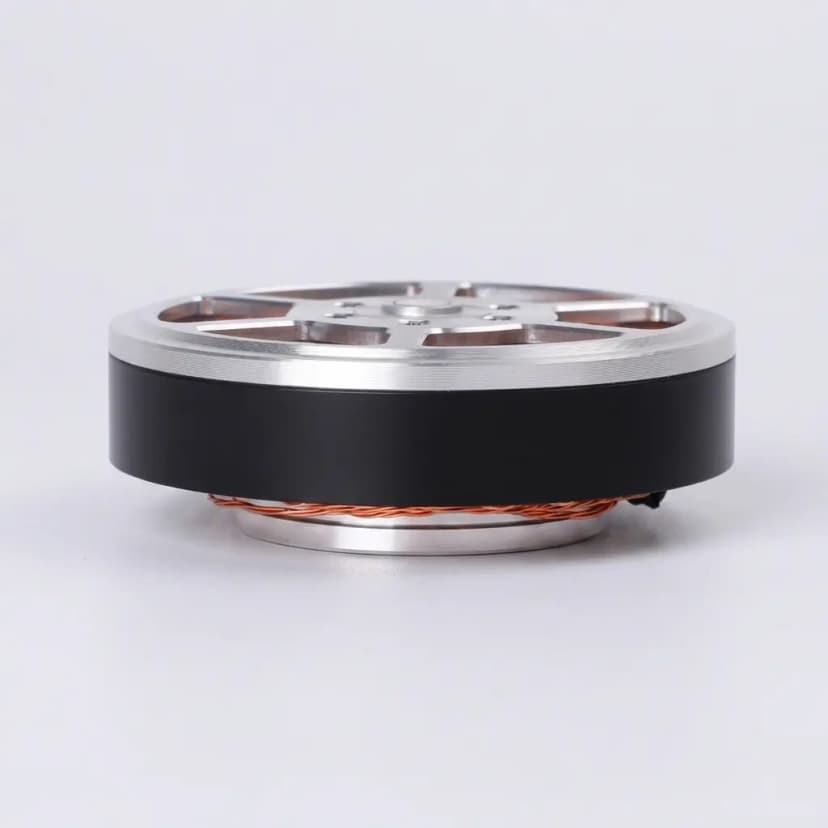
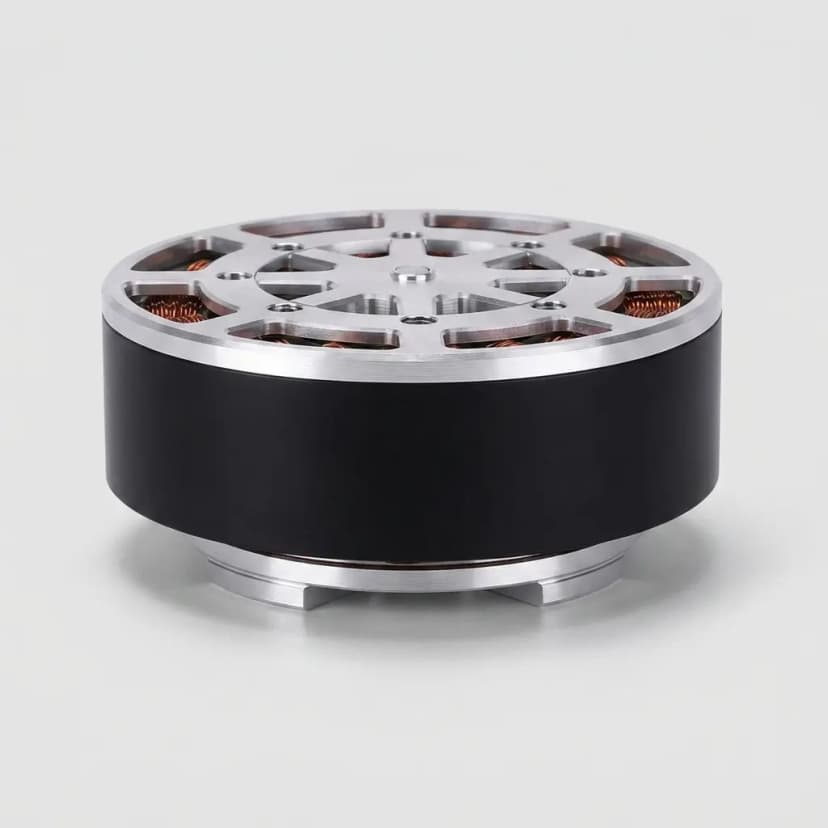
Outer-rotor brushless torque motor for backdrivable robot joint review

Buyer FAQ

Do you certify complete exoskeleton systems?

No. We support actuator-level selection and OEM supply. Final system safety, medical, or wearable certification belongs to the system integrator.

Can QDD actuators be used for transparent torque control?

They can support torque-control-friendly designs when ratio, friction, encoder, driver, and controller choices are aligned.

Related Resources

Inquiry Email

[email protected]

Include robot type, joint location, torque/speed/voltage targets, quantity, and destination.

Instant Chat

+86 18857971991

Send QDD actuator specs, STEP files, or actuator references for engineering review.