← Back to Engineering

Backdrivability and Reflected Inertia

How backdrive torque, friction, ratio, and reflected inertia shape QDD actuator feel, force-control behavior, and robot impact response.

Best Fit:Best for teams comparing QDD modules against high-ratio joints or series-elastic concepts.
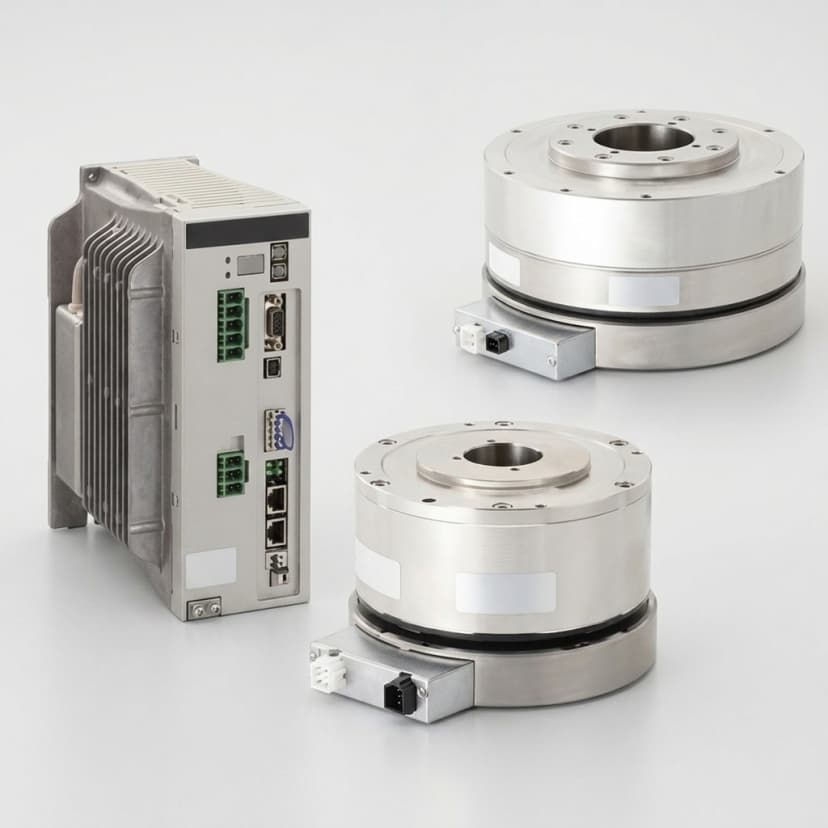
High-torque QDD actuator module for legged robot and exoskeleton joints

Key Takeaways

  • Backdrivability is not one number; friction, ratio, and motor/control choices interact
  • Lower reflected inertia can improve interaction and collision behavior
  • Static holding requirements should be separated from dynamic torque-control needs

Where This Applies

  • Force-control actuator selection
  • Wearable and interactive robot joints
  • Legged robot impact review

Engineering Focus

  • Backdrive torque, friction, cogging, and seal/bearing effects
  • Reflected inertia from gear ratio and rotor inertia
  • Holding torque, brake strategy, and control-loop implications

Engineering Decision Summary

A buyer should leave this note with a testable decision framework: which variables matter, what evidence is missing, and whether the actuator should move into sample selection.

Best Evidence

Start with backdrive torque and connect it to the real robot duty cycle instead of reviewing catalog values alone.

Primary Risk

Backdrivability is specified without a measurement method

Next Buyer Action

Prepare desired backdrive feel or reference actuator plus validation targets before requesting samples or commercial terms.
How to Use This Engineering Note

Engineering notes should help a buyer make a practical decision, not only define terminology. Use the criteria below to convert the concept into a sample-review plan.

Backdrive torque

0.3–1.5 Nm (QDD 6:1) vs 8–25 Nm (harmonic 80:1) vs non-backdrivable

Determines how much external torque is needed to move the joint.

Reflected inertia

J_reflected = J_motor × n²; 0.03 kg·m² at 6:1, 5.1 kg·m² at 80:1

High reflected inertia can make a joint feel harsher in interaction and impact.

Evidence to Collect During Review

The note is most useful when the buyer turns the concept into measurable checks during prototype review.

Signal to CheckReview BasisEvidence to Ask For
Backdrive torque0.3–1.5 Nm (QDD 6:1) vs 8–25 Nm (harmonic 80:1) vs non-backdrivableDefine test method, reference actuator, or practical interaction scenario before comparing samples.
Reflected inertiaJ_reflected = J_motor × n²; 0.03 kg·m² at 6:1, 5.1 kg·m² at 80:1Define test method, reference actuator, or practical interaction scenario before comparing samples.

Acceptance Thresholds to Define

Define measurable pass/fail thresholds before the sample arrives. This prevents a subjective review where one team checks torque, another checks packaging, and nobody records whether the actuator can move toward pilot build.

  • Backdrive torque: Determines how much external torque is needed to move the joint.
  • Reflected inertia: High reflected inertia can make a joint feel harsher in interaction and impact.

Where This Guidance Has Limits

The guidance is a selection framework. Final actuator fit still depends on the complete robot system, controller, and validation result.

  • Backdrivability is specified without a measurement method: Define test method, reference actuator, or practical interaction scenario before comparing samples.

Data That Makes the Review Actionable

When sending an engineering question, include enough context for the supplier to answer with constraints and next tests instead of a generic definition.

Fixed Constraints

  • Desired backdrive feel or reference actuator
  • External force or impact scenario

Review Targets

  • Static holding requirement and brake need
  • Encoder, current control, and controller constraints

Engineering Image References

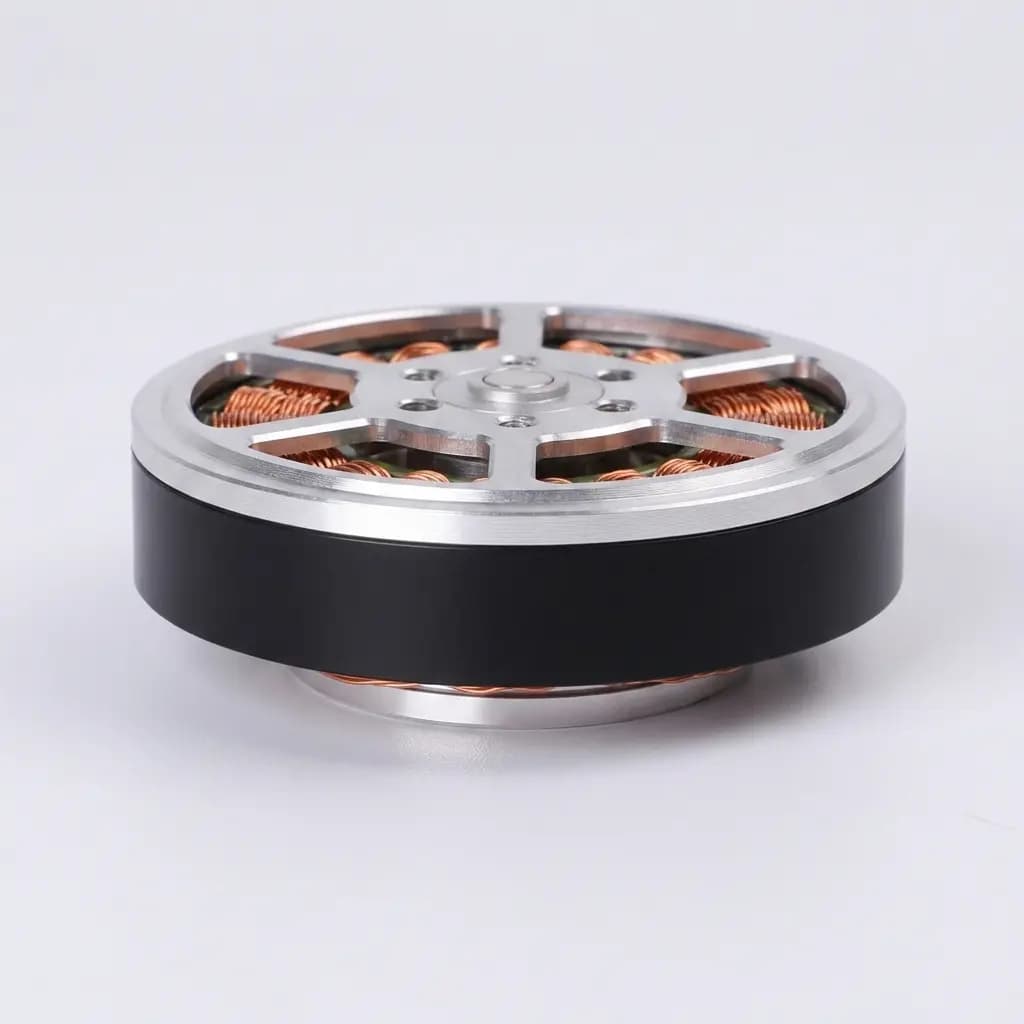
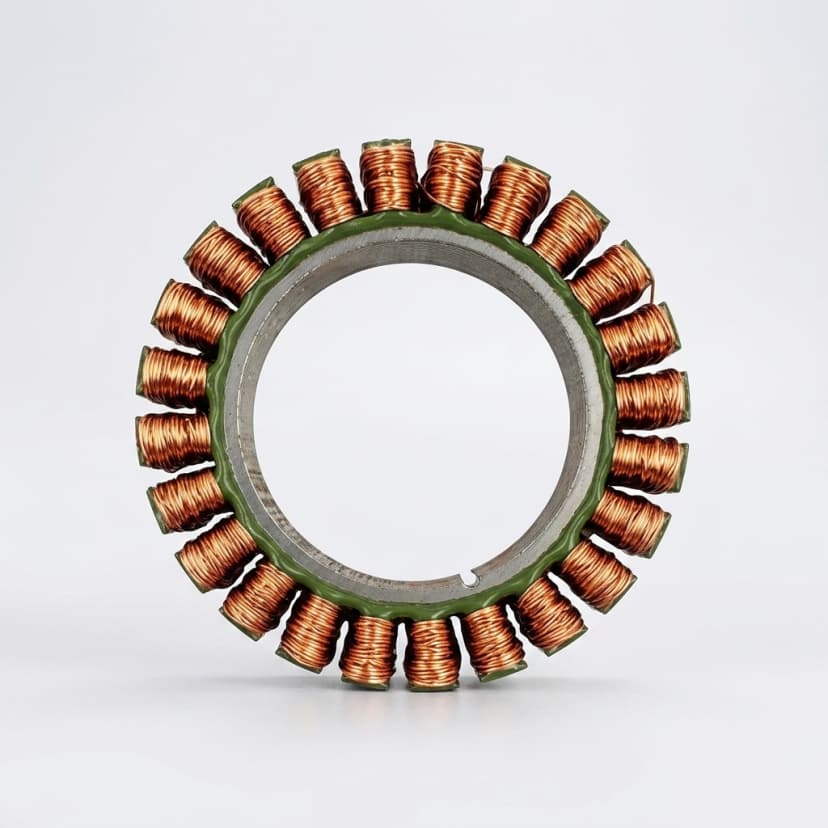
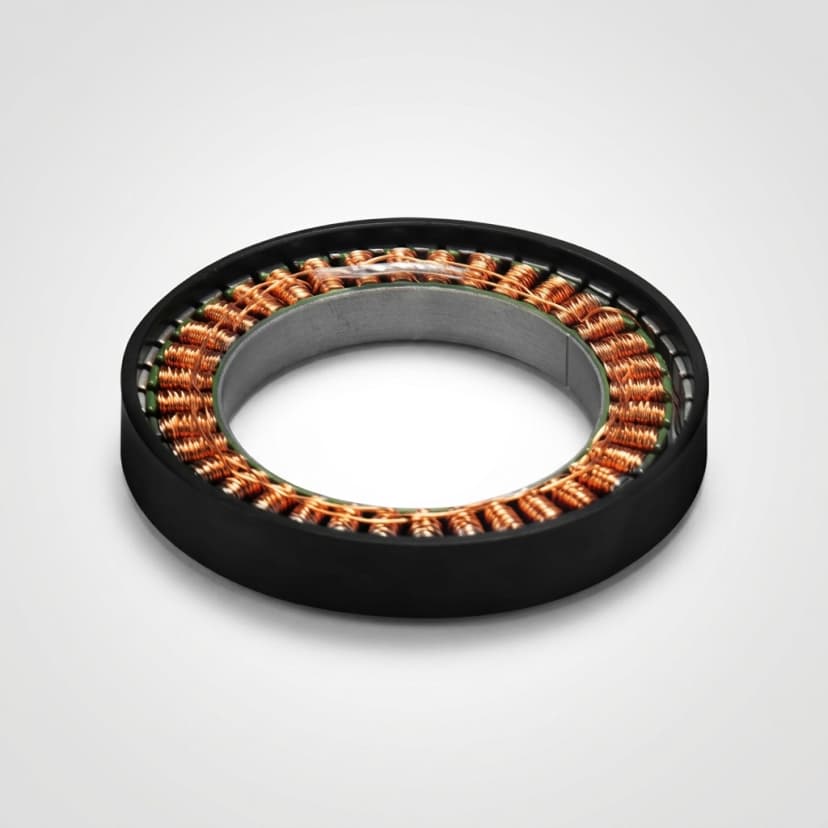
Product photos are used here as architecture references for buyer-side discussion. Final actuator selection depends on the validated joint envelope, ratio, torque-speed duty, and interface requirements.

Outer-rotor torque robot joint module for high-torque actuator review
Outer-rotor brushless torque motor for backdrivable robot joint review
Direct-drive motor reference for reflected-inertia comparison

Selection Criteria

CriterionTypical ReviewWhy It Matters
Backdrive torque0.3–1.5 Nm (QDD 6:1) vs 8–25 Nm (harmonic 80:1) vs non-backdrivableDetermines how much external torque is needed to move the joint.
Reflected inertiaJ_reflected = J_motor × n²; 0.03 kg·m² at 6:1, 5.1 kg·m² at 80:1High reflected inertia can make a joint feel harsher in interaction and impact.

Sample Review Inputs

  1. Desired backdrive feel or reference actuator
  2. External force or impact scenario
  3. Static holding requirement and brake need
  4. Encoder, current control, and controller constraints

Risk Controls

  • Backdrivability is specified without a measurement method: Define test method, reference actuator, or practical interaction scenario before comparing samples.

Buyer FAQ

Can a QDD actuator be backdriven by hand?

It depends on ratio, friction, motor design, seals, brake state, and controller state, so it should be validated on the intended sample.

Related Resources

Inquiry Email

[email protected]

Include robot type, joint location, torque/speed/voltage targets, quantity, and destination.

Instant Chat

+86 18857971991

Send QDD actuator specs, STEP files, or actuator references for engineering review.